Industrial automation applications
Robotic Depalletizing Systems
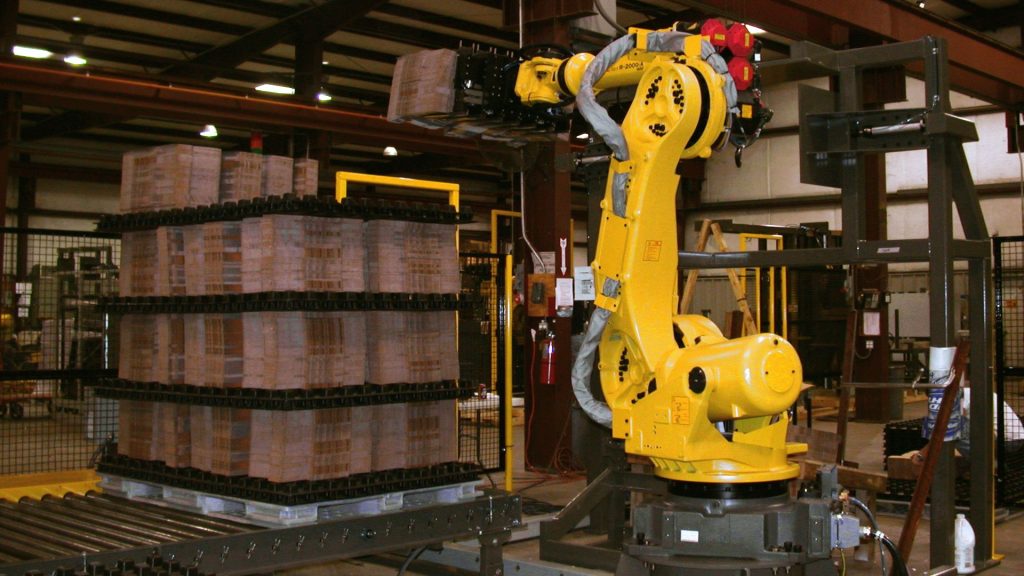
Sage designs robotic depalletizing systems that remove products reliably from layered, patterned or variable inbound loads and introduce them into production.
Reliable unloading begins with understanding load variation
Inbound pallets may shift during transport, arrive with damaged packaging or vary by supplier and SKU. Sage evaluates the expected load condition, product surface and separation method before selecting tooling, sensing and robot motion.
A depalletizing cell can include load positioning, layer detection, vision, sheet removal, empty-pallet handling, product conveyors and exception recovery. FANUC articulated robots or Sage gantries are selected according to payload, reach, rate and access requirements.
Application data to define
- Inbound pallet consistency
- Product damage and packaging variation
- Layer sheets, straps and wrapping
- Required discharge orientation
- Empty-pallet and dunnage handling
- Exception and manual-recovery strategy
What the system can include
Layer and case handling
Remove full layers or individual products according to rate, stability and downstream process requirements.
Variable load detection
Use sensing or vision when pallet position, stack height or product arrangement cannot be assumed.
Downstream presentation
Orient, meter and convey unloaded products so the next operation receives a controlled flow.
Frequently asked questions
Do depalletizing systems require vision?
Not always. Highly repeatable loads may use fixed positions or sensing, while variable stacks and mixed products often benefit from 2D or 3D vision.
Can the same cell palletize and depalletize?
In some applications a shared robot can perform both functions, provided the layout, tooling, cycle time and production schedule support the combined operation.
Continue your application research
Bring us the application data.
Share the product, payload, rate, process sequence and available layout with a Sage applications engineer.